Robotic fingers can now handle thin solder wire and adjust their grip using artificial skin. It can process touch signals in about 23 milliseconds.
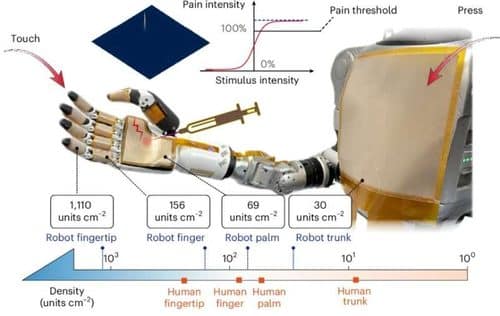
Researchers at Southern University of Science and Technology in China and collaborating institutions have developed an artificial skin system for robotic fingers. The artificial skin allows robotic hands to sense touch and process sensory signals quickly. For example, a robotic arm covered with this skin can grasp a fragile pencil lead and pull away from a needle before it punctures the covering. The researchers claim that it can read more than 10,000 sensing elements 100 times a second and process the information in stages.
Many artificial skins have a common problem of delays in responses. The skin struggles to process touch signals quickly and accurately when it has thousands of sensing points. The new skin developed solves this problem by combining flexible electrodes with a soft gel containing electrically charged particles. It works on the concept that changes in pressure, in turn, change the electrical response where the gel meets the electrodes, allowing the system to measure touch signals accurately.
Now, to read many sensing points together, the team assigned them different signal frequencies within each sensor bundle. These signals can also be separated even when they arrive together. The different signal frequencies identify the sensing point, and their signal strength indicates pressure. The proposed circuitry also avoids interference between neighbouring sensors. For example, there are thousands of sensors that detect touch, but the system need not send every raw signal for detailed analysis.
For testing, the team tested whether useful detail would survive that compression. With a 268-fold reduction in data, the system was still able to distinguish among 10 everyday object categories with 98.2% accuracy. The full sequence from sensing through interpretation took about 23 milliseconds.
The robotic finger covered with the artificial skin was able to handle soft solder wire only 0.2 millimetres thick. When the thickness of the wire changed, the fingers adjusted their positions to keep it from falling. At the same time, protecting the skin is also necessary, so the team designed an artificial ‘pain signal’ that warns the robot when something might damage its skin.
Currently, the artificial skin detects touch, but the electronic circuits that process these signals take up a lot of space. One way is to put these circuits onto custom-made chips, which can bring the electronics that interpret touch closer to the flexible covering that detects it.